I am a fifth-year PhD student at Carnegie Mellon University studying Electrical and Computer Engineering, advised by Prof. Guannan Qu and Prof. Yorie Nakahira. I obtained my M.S. degree at Duke University in Computer Science in 2022. I obtained my B.S. degree in Honors math and computer science at University of Michigan, Ann Arbor, in 2021.
My current research interests are in stochastic control, reinforcement learning, and diffusion models. I study how to learn and control unknown dynamical systems with provable guarantees, and I work on both the theory and the applications of diffusion models, from their convergence on manifolds to topology-aware 3D generation. More broadly, I am interested in graph theory, algebraic topology and their applications in machine learning.
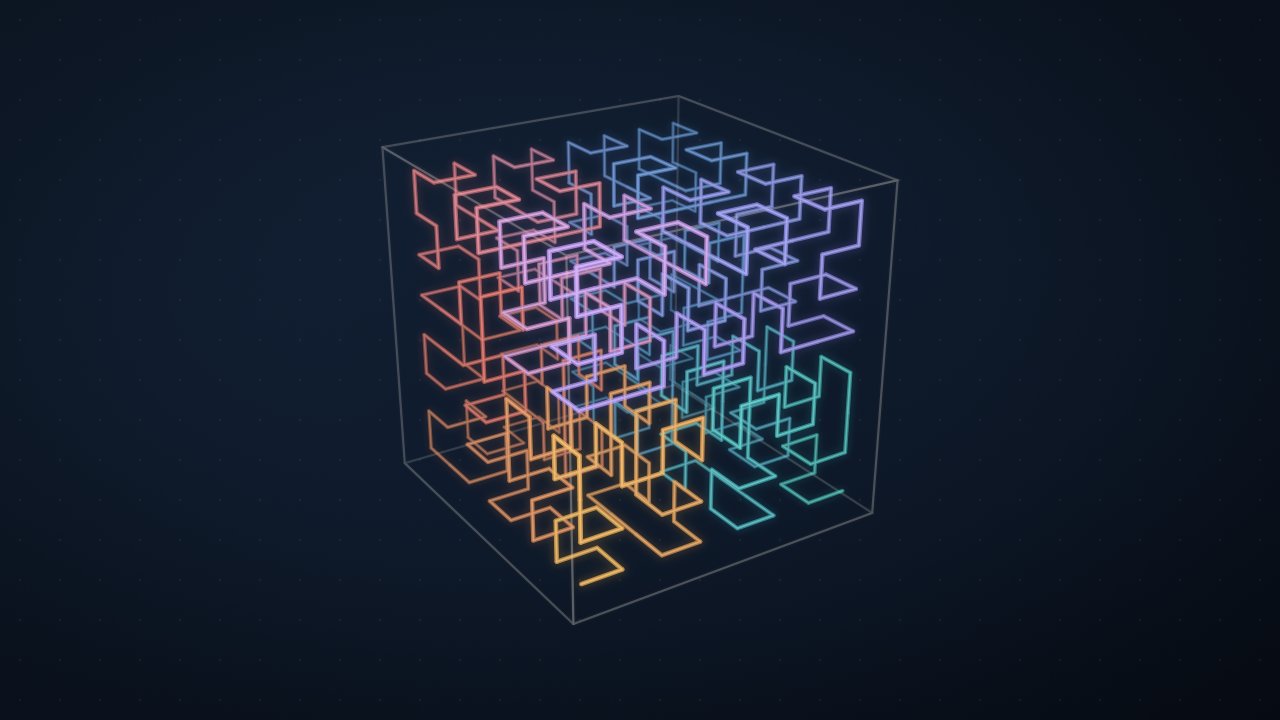
High-fidelity 3D generative modeling underpins game asset creation, medical imaging, and VR/AR environmental design, where geometric structure directly influences perception and decision-making. Diffusion models represent a powerful paradigm for point cloud generation. However, existing approaches rely heavily on local voxel or patch features and often miss global structural organization, and much less work has studied how global conditioning can be used to improve generation quality. In this paper, we introduce HilbertGen-3D, a novel topology-aware conditional diffusion framework based on Hilbert-Multifractal Conditioning (HMC). HMC computes multi-scale voxel measures, serializes them via a 3D Hilbert curve to expose structured spatial dependencies, and estimates the generalized fractal dimensions from scale-dependent partition functions. We encode these signals as global embeddings and multi-scale tokens, and inject them into a diffusion denoiser through an efficient bottleneck fusion module. Across the Chair, Airplane, and Car categories of ShapeNet, our two conditioning variants reduce the absolute deviation of 1-Nearest Neighbor Accuracy (1-NNA) from 50% by up to 8.90 percentage points and increase coverage by up to 5.88 percentage points relative to TopoDiT-3D. This shows that combining local density cues with global Hilbert-multifractal structure provides a simple and effective recipe for high-fidelity and diverse 3D generation.
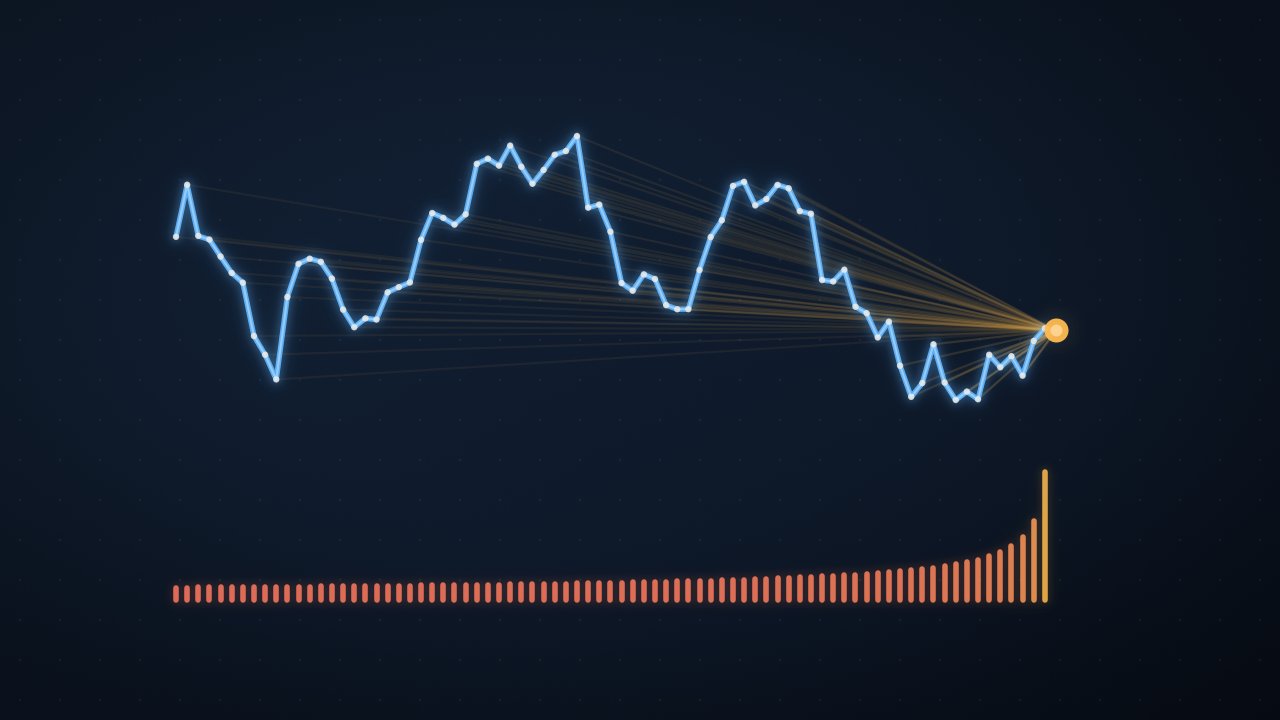
Many real-world processes exhibit long-range dependence, where the current state depends on a slowly decaying trace of past states rather than on the most recent state alone. This paper studies system identification for discrete-time fractional-order linear time-invariant systems from a single observed trajectory of length t, a setting that captures such non-Markovian dynamics through the Grünwald–Letnikov difference operator. Unlike Markovian systems, fractional-order systems couple estimation across the entire history, making both statistical analysis and practical identification more challenging. We propose Fractional-Order Ordinary-Least-Squares Grid-Search (FO-GS), a simple two-stage estimator that exploits the diagonal structure of the fractional-difference operator to decouple the identification problem row-wise. Under the stability assumption, we establish high-probability, non-asymptotic error bounds for estimating both the fractional order and the system matrix in the heterogeneous setting, with both estimation errors scaling as O(t−1/2). Through experiments, we show that FO-GS outperforms existing baselines in recovering both the fractional order and the underlying system dynamics.
Diffusion models have demonstrated remarkable empirical success in the recent years and are considered one of the state-of-the-art generative models in modern AI. These models consist of a forward process, which gradually diffuses the data distribution to a noise distribution spanning the whole space, and a backward process, which inverts this transformation to recover the data distribution from noise. Most of the existing literature assumes that the underlying space is Euclidean. However, in many practical applications, the data are constrained to lie on a submanifold of Euclidean space. Addressing this setting, De Bortoli et al. (2022) introduced Riemannian diffusion models and proved that using an exponentially small step size yields a small sampling error in the Wasserstein distance, provided the data distribution is smooth and strictly positive, and the score estimate is L∞-accurate. In this paper, we greatly strengthen this theory by establishing that, under L2-accurate score estimate, a polynomially small stepsize suffices to guarantee small sampling error in the total variation distance, without requiring smoothness or positivity of the data distribution. Our analysis only requires mild and standard curvature assumptions on the underlying manifold. The main ingredients in our analysis are Li-Yau estimate for the log-gradient of heat kernel, and Minakshisundaram-Pleijel parametrix expansion of the perturbed heat equation. Our approach opens the door to a sharper analysis of diffusion models on non-Euclidean spaces.
We study the problem of stabilizing an unknown partially observable linear time-invariant (LTI) system. For fully observable systems, leveraging an unstable/stable subspace decomposition approach, state-of-art sample complexity is independent from system dimension n and only scales with respect to the dimension of the unstable subspace. However, it remains open whether such sample complexity can be achieved for partially observable systems because such systems do not admit a uniquely identifiable unstable subspace. In this paper, we propose LTS-P, a novel technique that leverages compressed singular value decomposition (SVD) on the ‘‘lifted’’ Hankel matrix to estimate the unstable subsystem up to an unknown transformation. Then, we design a stabilizing controller that integrates a robust stabilizing controller for the unstable mode and a small-gain-type assumption on the stable subspace. We show that LTS-P stabilizes unknown partially observable LTI systems with state-of-the-art sample complexity that is dimension-free and only scales with the number of unstable modes, which significantly reduces data requirements for high-dimensional systems with many stable modes.
We study the problem of learning to stabilize unknown noisy Linear Time-Invariant (LTI) systems on a single trajectory. It is well known in the literature that the learn-to-stabilize problem suffers from exponential blow-up in which the state norm blows up exponentially in the state dimension. This blow-up is due to the open-loop instability when exploring the n-dimensional state space. To address this issue, we develop a novel algorithm that decouples the unstable subspace of the LTI system from the stable subspace, based on which the algorithm only explores and stabilizes the unstable subspace, the dimension of which can be much smaller than n. With a new singular-value-decomposition(SVD)-based analytical framework, we prove that the system is stabilized before the state norm is only exponential in the order of the dimension of the unstable subspace and is advantagous if the unstable subspace is small. Critically, this bound avoids exponential blow-up in state dimension as in the previous works, and to the best of our knowledge, this is the first paper to avoid exponential blow-up in dimension for stabilizing LTI systems with noise.
Autonomous systems must have the ability to quickly adapt to various situations. However, adaptation methods often require strong assumptions about system structures, environmental homogeneity, and multiple rollouts. In this work, we integrate multi-armed bandit and model-based RL to design a fast adaptation algorithm on a single trajectory. Our approach achieves sublinear regret, and the performance guarantee does not require homogeneity of the environment. This regret bound is achieved using a novel prediction error metric that is minimized in the ground-truth MDP. To the best of our knowledge, all existing results with provable guarantees depend on the Bregman divergence between the optimal policies among the MDP’s. We show by simulation that our algorithm performs well in puzzle navigation and quadcopter path-tracking.
Policy design in non-stationary Markov Decision Processes (MDPs) is inherently challenging due to the complexities introduced by time-varying system transition and reward, which make it difficult for learners to determine the optimal actions for maximizing cumulative future rewards. Fortunately, in many practical applications, such as energy systems, look-ahead predictions are available, including forecasts for renewable energy generation and demand. In this paper, we leverage these look-ahead predictions and propose an algorithm designed to achieve low regret in non-stationary MDPs by incorporating such predictions. Our theoretical analysis demonstrates that, under certain assumptions, the regret decreases exponentially as the look-ahead window expands. When the system prediction is subject to error, the regret does not explode even if the prediction error grows sub-exponentially as a function of the prediction horizon. We validate our approach through simulations, confirming the efficacy of our algorithm in non-stationary environments.
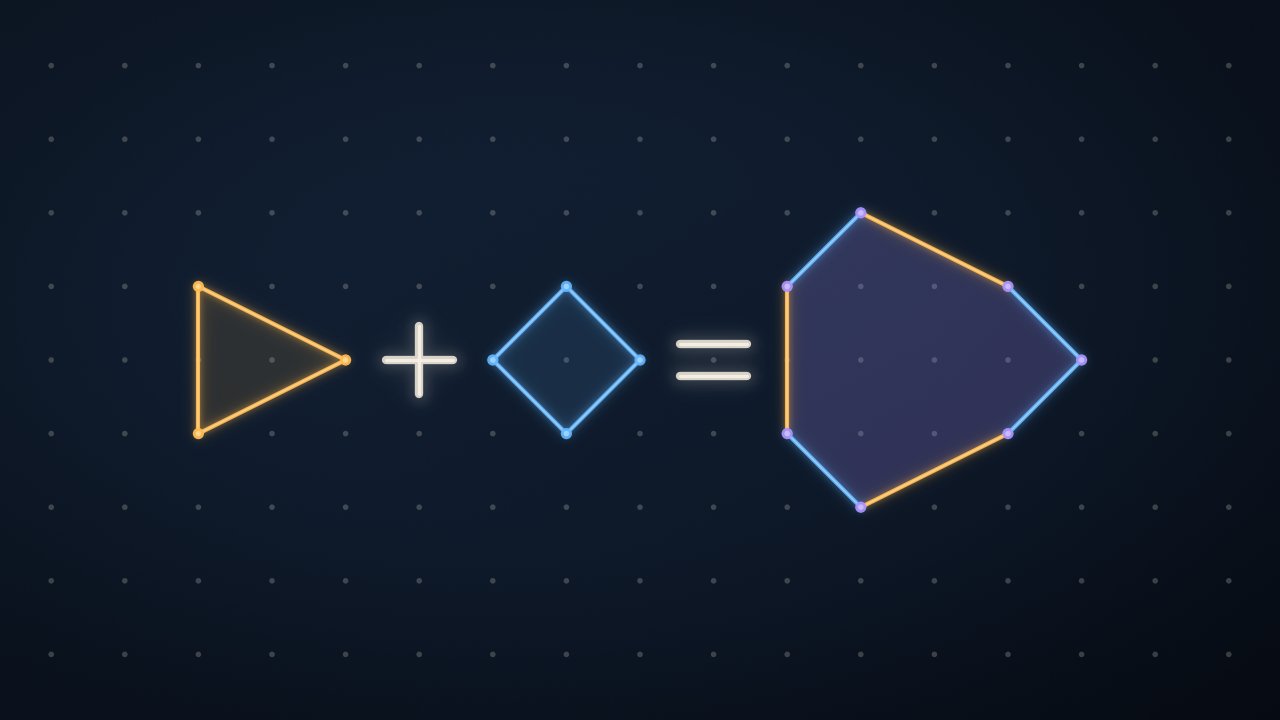
We classify all tuples of lattice polyhedra of relative mixed volume 1 and all minimal (by inclusion) tuples of polyhedra of relative mixed volume 2. We also prove a conjecture by Esterov, which states that all tuples with finite relative mixed volume are contained in one of finitely many ones that are minimal by inclusion.
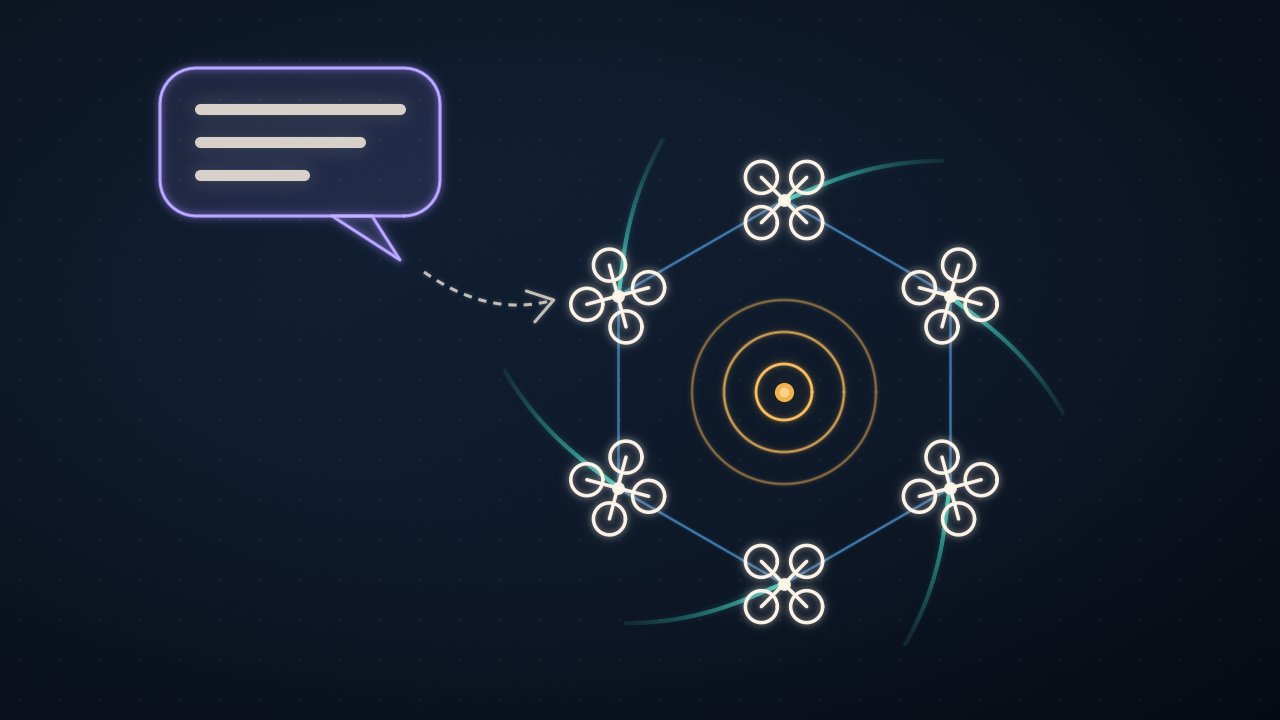
We study language-in-the-loop control for multi-drone systems that execute evolving, high-level missions while retaining formal robustness guarantees at the physical layer. We propose a three-layer architecture in which (i) a human operator issues natural-language instructions, (ii) an LLM-based supervisor periodically interprets, verifies, and corrects the commanded task in the context of the latest state and target estimates, and (iii) a distributed inner-loop controller tracks the resulting reference using only local relative information. We derive a theoretical guarantee that characterizes tracking performance under bounded disturbances and piecewise-smooth references with discrete jumps induced by LLM updates. Overall, our results illustrate how centralized language-based task reasoning can be combined with distributed feedback control to achieve complex behaviors with provable robustness and stability.
Experience
Summer 2026
Software Engineer Intern (Gmail Ads), Google LLC, Sunnyvale, CA
Built an LLM-based agentic system to adjust bidding parameters produced by the hidden distribution model for impressions.
Summer 2025
AI System Intern, Aira Technologies Inc., Saratoga, CA
Designed and implemented an agentic LLM network for root cause analysis (RCA) in AT&T network.
Summer 2020
Software Engineer, Guochuang Software Co.
Designed a commercial website using HTML and JavaScript.